

YUBI-Real2Sim evaluates robot policies in MuJoCo with 3D Gaussian backgrounds
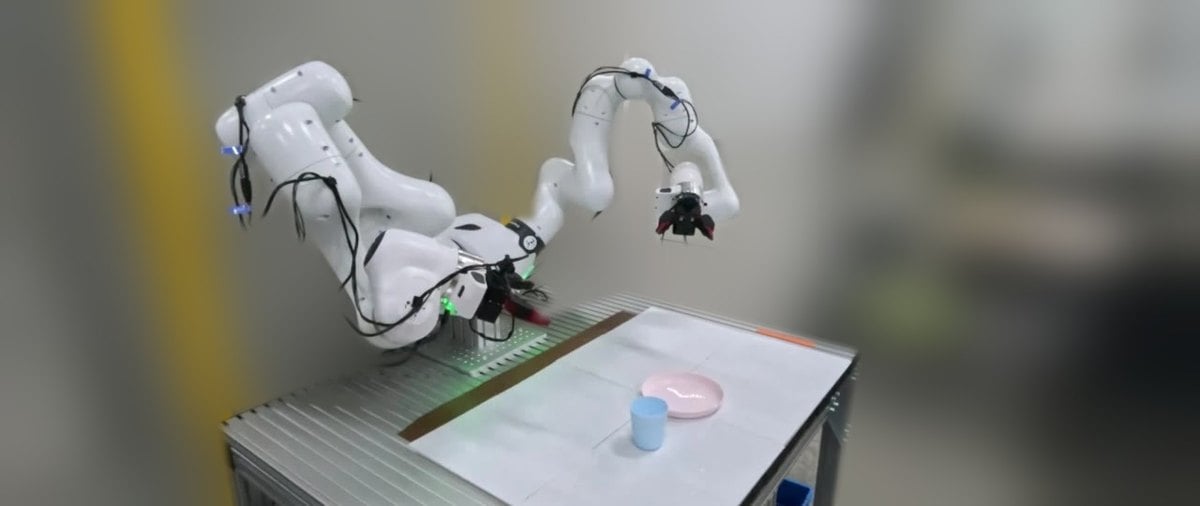
The airoa-org/yubi-real2sim repository was created on 4 November 2026. Its README describes a simulator that evaluates an OpenPI pi-0.5 policy on a Franka FR3 with bimanual YUBI in MuJoCo, using a 3D Gaussian Splatting room capture as the background, on a cup-on-a-plate task that writes scored rollouts, logs, videos and a summary.
The repository code is Apache-2.0, but the included 3DGS renderer (GaussianWrapping) is non-commercial, so the full pipeline cannot be used commercially. The README links a project page and an October arXiv paper; the GitHub project itself appeared on this date.