

TerraTransfer++ trains end-to-end driving planners without human demonstrations, and tests them in 3DGS
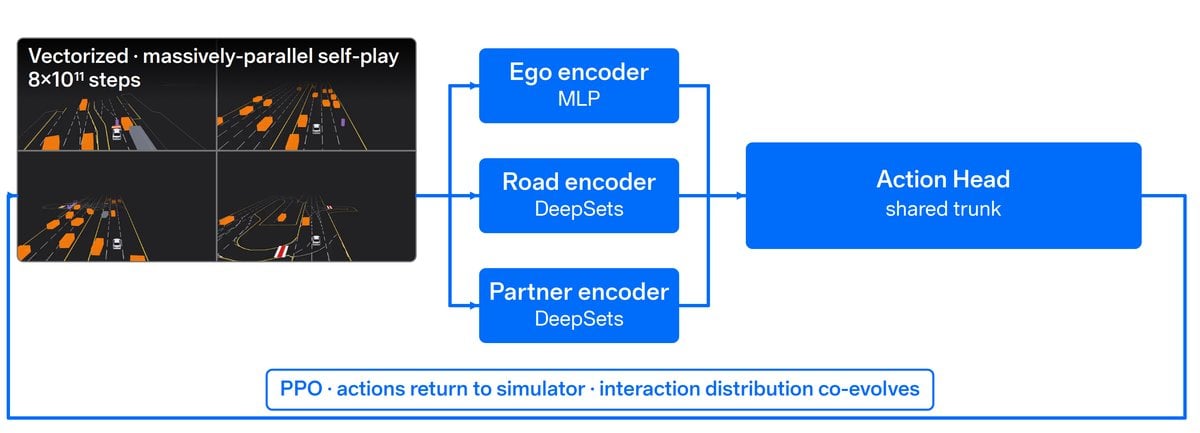
Zikang Xiong, Weixin Li, Zhouchonghao Wu and colleagues present TerraTransfer++, a demonstration-free recipe for end-to-end autonomous driving. A policy is pretrained by self-play in a vectorized simulator, its rollouts are distilled into a flow-matching trajectory teacher, and lightweight adapters on a frozen vision backbone are trained to reproduce that teacher’s latent space, so alignment never supervises against a logged trajectory.
From that one self-play teacher the authors obtain a closed-loop policy that they say outperforms every published imitation-based end-to-end method on the photorealistic 3D Gaussian splatting benchmark HUGSim, and a planner that reaches 59.4 EPDMS on NAVSIM navhard, above DriveZero-Scale at 57.1, and 95.5 PDMS on navtest, without human demonstrations.