

SG²SLAM couples streaming spatial geometry with a ray-conditioned 3DGS kernel
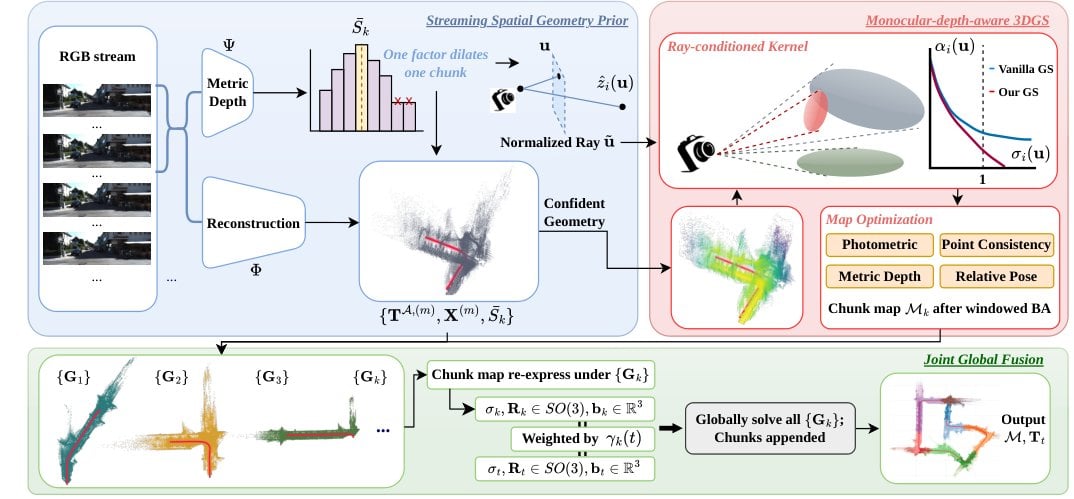
Ziang Guo, Didar Seyidov, Yixiao Zhou and colleagues present SG²SLAM, a monocular outdoor 3D Gaussian Splatting SLAM system. They argue that typical pipelines recover geometry by associating 2D pixels with 3D points, so a modular SLAM system absorbs tracking error into the map.
SG²SLAM replaces per-frame cross-dimensional correspondence with a chunk-level metric prior that supervises tracking and mapping from one source, and a ray-conditioned kernel extends each primitive with a viewing-direction subspace. Joint optimization over spatial geometry and poses aims for a globally consistent map and trajectory. On KITTI and Waymo Open, the authors report that SG²SLAM surpasses per-frame association baselines for monocular outdoor navigation.