

SG-Splat stabilizes pose-free feed-forward 3DGS under residual pose error
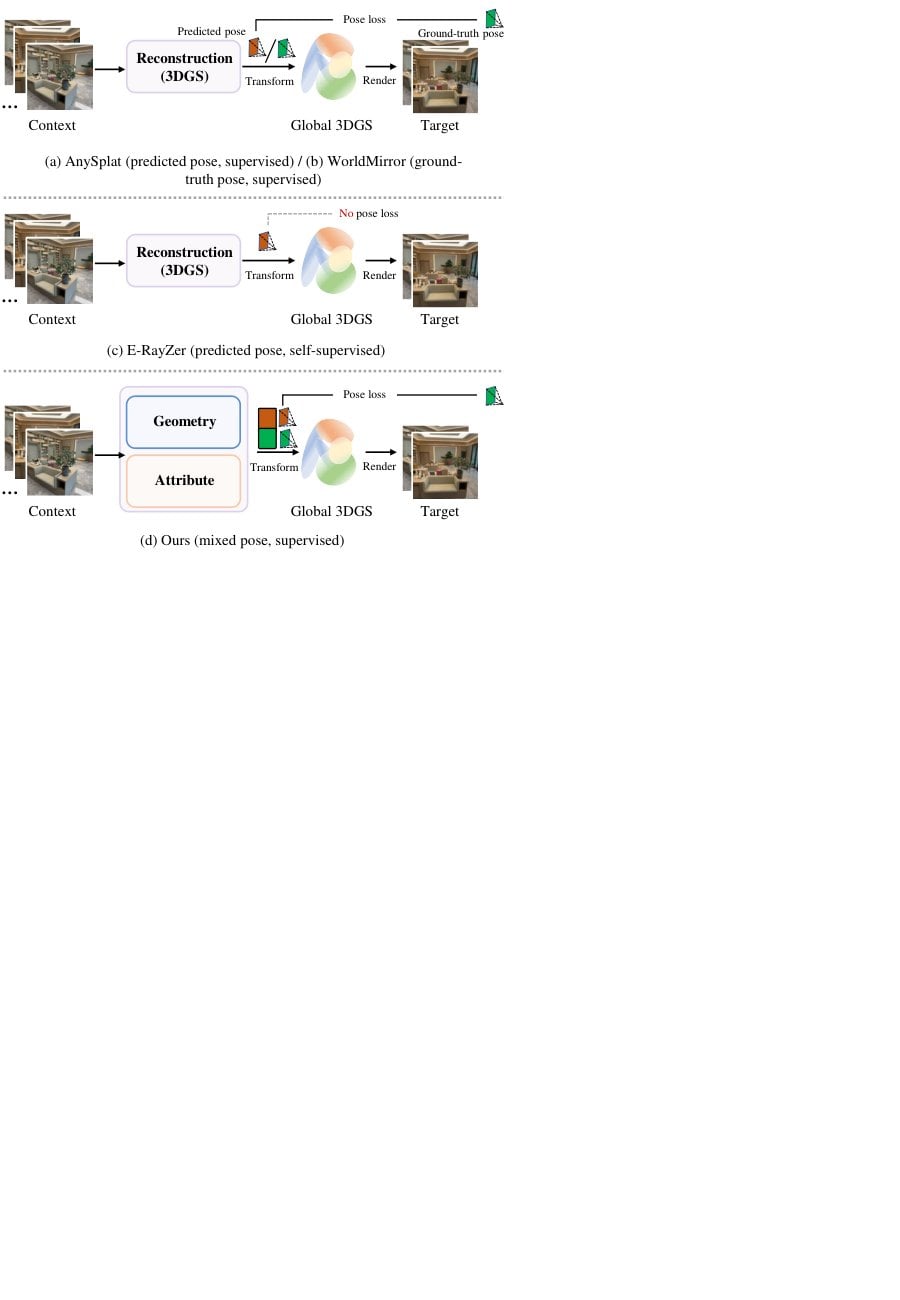
Xiaohan Lu, Jiaqi Zhang, Weijia Jiang and Siwei Ma present SG-Splat, a pose-free feed-forward 3D Gaussian Splatting framework designed to be more robust to residual pose errors. Geometry estimation and Gaussian attribute prediction are decoupled into two branches, and a coarse-to-fine pipeline first refines camera poses with flow-based correlation and differentiable bundle adjustment, then corrects initial point maps with depth residuals before attribute reconstruction.
A dual-path training strategy mixes ground-truth and predicted poses for canonical transformation. On DL3DV and RealEstate10K, the authors report state-of-the-art performance in both novel-view synthesis and pose estimation.