

RoMo-GS integrates motion blur over the exposure interval for online robot mapping
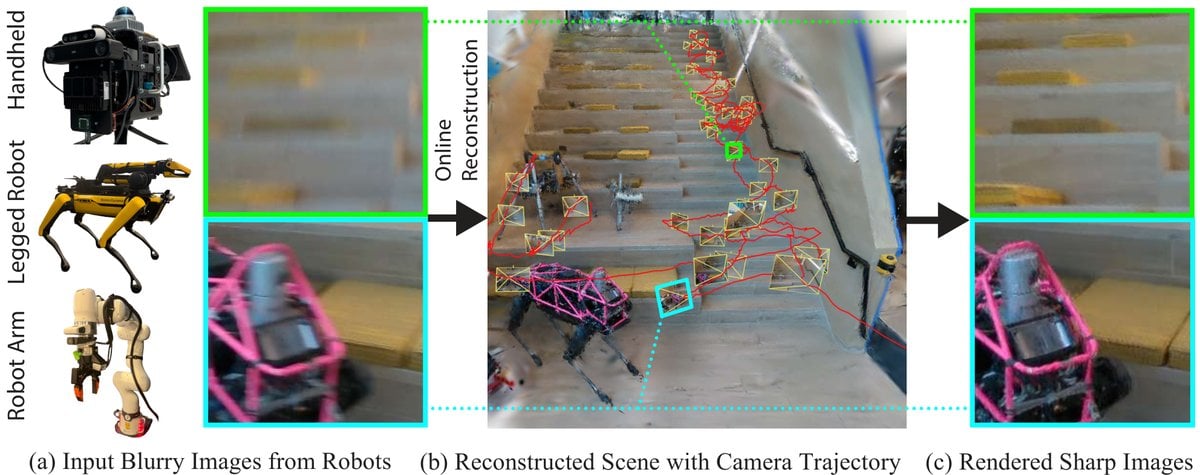
Sangwoo Jung, Di Deng, Jiahui Fu, Laura Herlant, Ayoung Kim and Yafei Hu present RoMo-GS, an online 3D Gaussian Splatting system for robot mapping that addresses motion-blurred images from rapid maneuvers and unbounded Gaussian growth. Instead of averaging N discrete sub-frames, it analytically integrates each projected Gaussian over the exposure interval at O(1) cost per Gaussian, and bounds growth with a Hessian-based pruning score while jointly refining pose, velocity and Gaussians.
On public datasets and a self-collected set, RoMo-GS matches or exceeds offline deblurring 3DGS methods in rendering quality while running 15–150× faster, and operates online at competitive quality with about 20% fewer Gaussians than an online 3DGS baseline.