

Robot-aligned 3DGS data helps a wrist-camera VLA reach cluttered e-waste parts
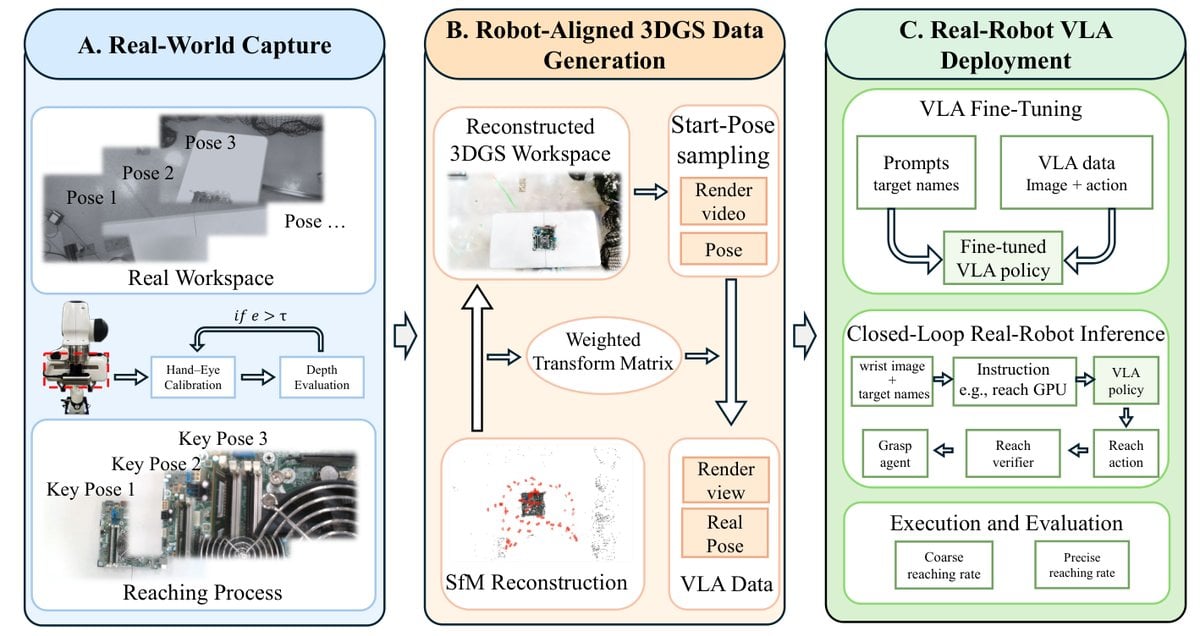
Zuoxu Wang and Xiao Liang present a 3D Gaussian Splatting data-generation pipeline for wrist-camera vision-language-action policies, aimed at pre-contact reaching in cluttered electronic-waste disassembly. The real workspace is reconstructed with 3DGS and diverse wrist-camera observations are rendered from robot-aligned poses, then paired with smooth reaching trajectories for VLA fine-tuning. An instruction-conditioned reach verifier estimates target proximity and provides reliable termination before contact.
In motherboard-disassembly experiments using wrist-camera observations alone, 1,500 generated trajectories with π0.5 achieve 80.0% precise-reaching success across three targets, compared with 58.7% using 150 teleoperated demonstrations, and require less than 10 minutes of active human capture.