

RigidGS decouples object identity from geometry for interactive Gaussian scenes
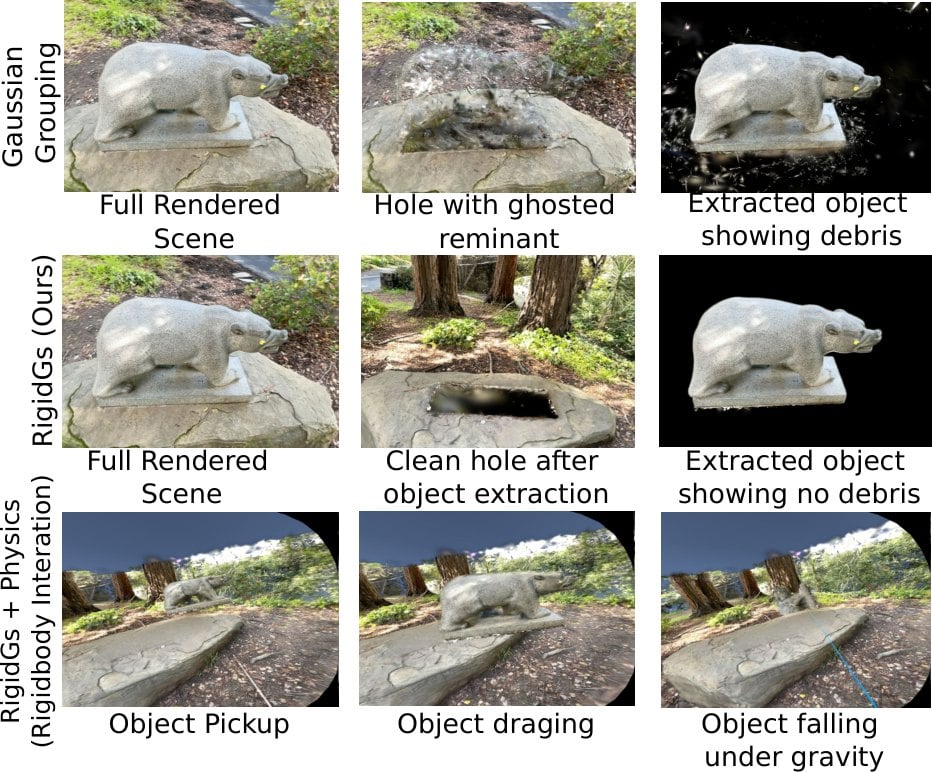
Paul Sansah Gyreyiri and Diksha Shukla present RigidGS, accepted to WACV 2027 (Applications Track), for object-level manipulation in 3D Gaussian Splatting scenes aimed at interactive VR and MR. They argue that methods which jointly optimize geometry and semantic identity suffer from noisy foundation-model masks and from label-geometry coupling that mislabels boundary Gaussians.
RigidGS determines object identities upstream via COLMAP projections and uses a depth- and temporally-aware mask refinement module to address two SAM2 failure modes: over-inclusion on thin structures and under-inclusion on objects with multimodal depth. Geometric learning is then kept separate from those identities.