

RelateGS refines unreliable semantics and under-observed relations for 3D grounding
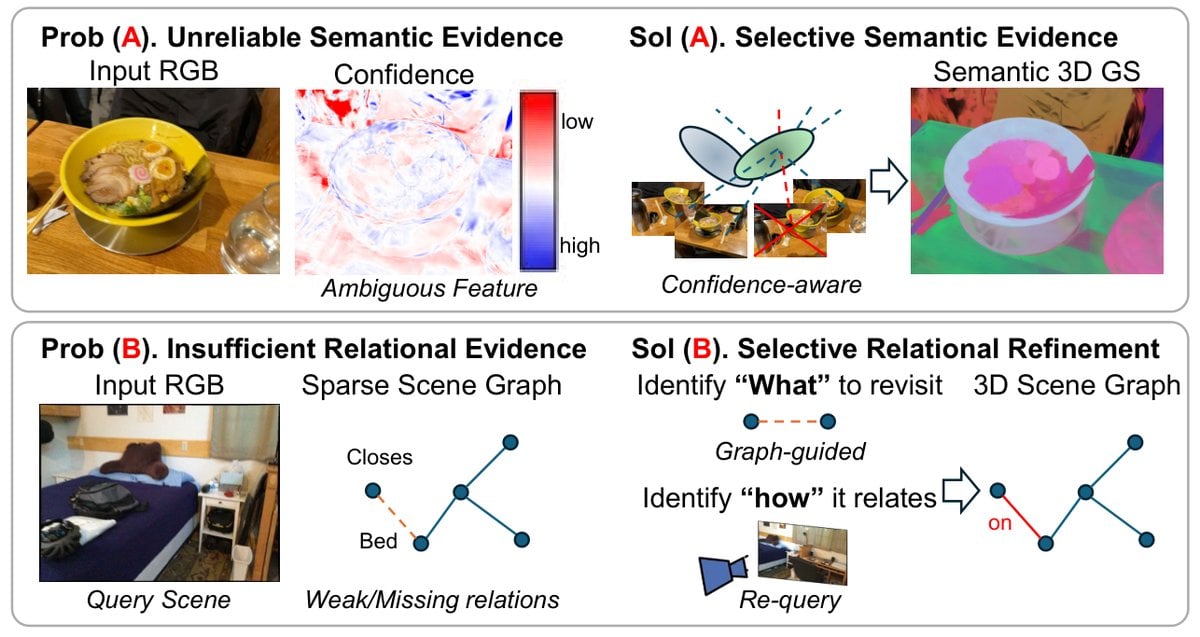
Seongjun Choi and Sangyoun Lee present RelateGS, a structured language-aware Gaussian representation for 3D visual grounding, accepted at WACV 2027. They argue that multi-view semantic aggregation can incorporate weak observations, and that object relations can remain under-observed along the available camera trajectory.
RelateGS suppresses unreliable observations during semantic feature uplifting, consolidates multi-view object observations into a persistent 3D graph, and guides targeted re-querying of informative existing frames to complement under-observed relations. On Sr3D+ and Nr3D it improves the previous best by 7.9 and 1.7 percentage points at Acc@0.25, respectively.
 «Unreliable Semantics» Comic