

PLS-GS builds a compact, surface-aligned Gaussian scene from camera and LiDAR
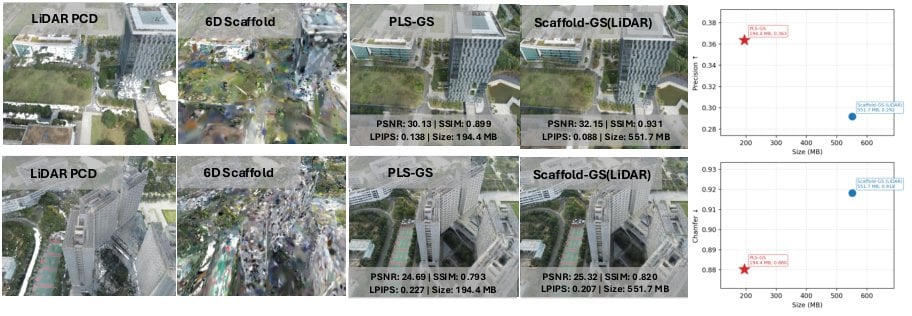
Krishnan Harikumar et al. introduce PLS-GS, accepted to WACV 2027, a probabilistic LiDAR scaffold for Gaussian Splatting when both camera images and high-definition LiDAR are available. A hierarchical Gaussian mixture is fitted jointly over position and color, giving a continuous adaptive scaffold that does not need voxel grids or octrees.
Each renderable 3DGS Gaussian is then tied to a mixture component and constrained in the local surface frame induced by that component’s covariance, with a Mahalanobis support loss limiting how far it may drift. The authors present this as a compact representation aligned to the measured surface.