

PanoGraphGS learns panoptic Gaussians and builds a floor-to-object scene graph
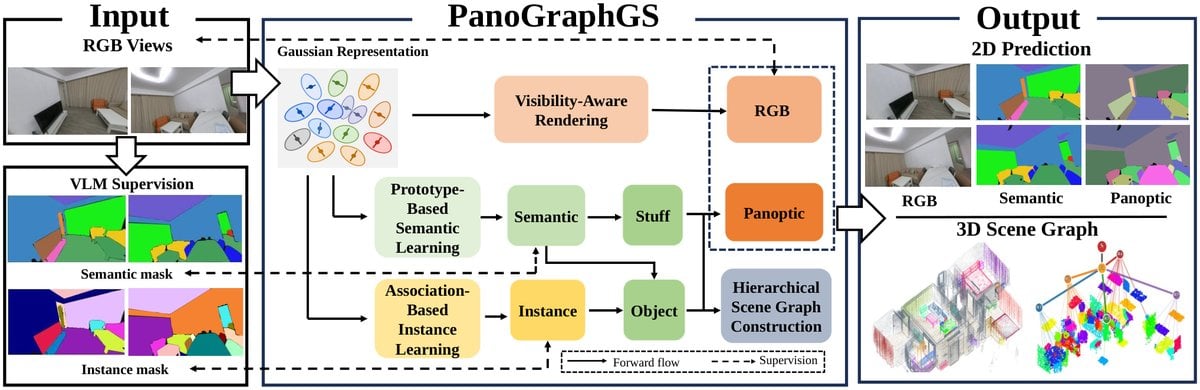
Jinghan Gao, Siyu Wang, Dongyu Feng, Yiyuan Pan and Rong Xiong present PanoGraphGS, which integrates panoptic 3D Gaussian representation learning with hierarchical 3D scene-graph construction. Semantic and instance features are learned on shared Gaussian geometry, supporting novel-view panoptic segmentation and direct Gaussian-level panoptic decoding, and a semantic-aware module recovers a floor-room-stuff-object hierarchy with containment and spatial relations.
The authors also release NaviGS, a real-world dataset with 3DGS, mesh, RGB, semantic and depth data. For 3D scene-graph identification, PanoGraphGS outperforms the strongest evaluated baseline in object-node accuracy by more than 50 percentage points on average across Replica and NaviGS, and also reports state-of-the-art 2D panoptic segmentation among the evaluated methods.