

OccSplat densifies feed-forward Gaussian driving scenes in occluded regions
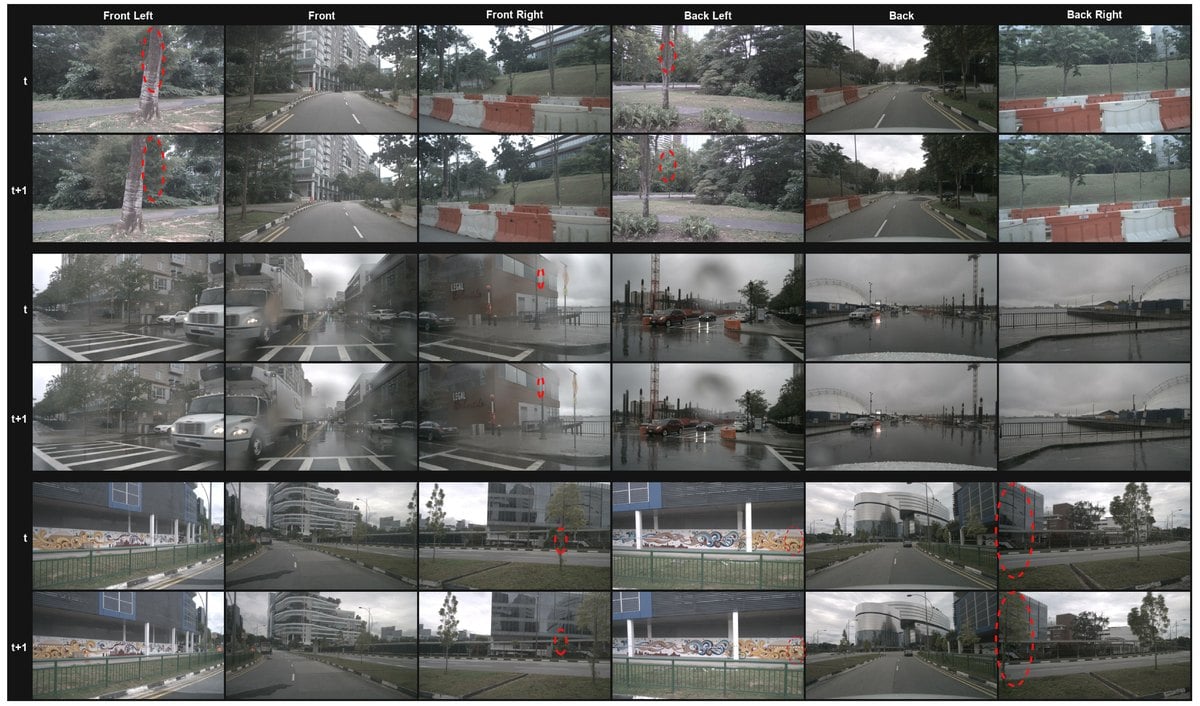
Dung Do Tien et al. introduce OccSplat, a feed-forward 3D Gaussian Splatting framework for driving-scene reconstruction that targets missing geometry rather than missing pixels. The paper, accepted to the ACCV 2026 CV4DC workshop, argues that single-observation feed-forward methods leave Gaussians under-constrained where input cameras cannot see, so novel viewpoints expose incomplete scenes.
Gaussian Occlusion Mapping finds regions without support, Gaussian Occlusion Completion predicts new primitives for those regions, and the added primitives are merged back into the representation without per-scene optimization. On nuScenes, the authors report particular gains in occluded regions and more coherent novel-view driving reconstructions than the compared methods.