

MoRE-GS forecasts a dynamic 3DGS scene with four motion-regime experts
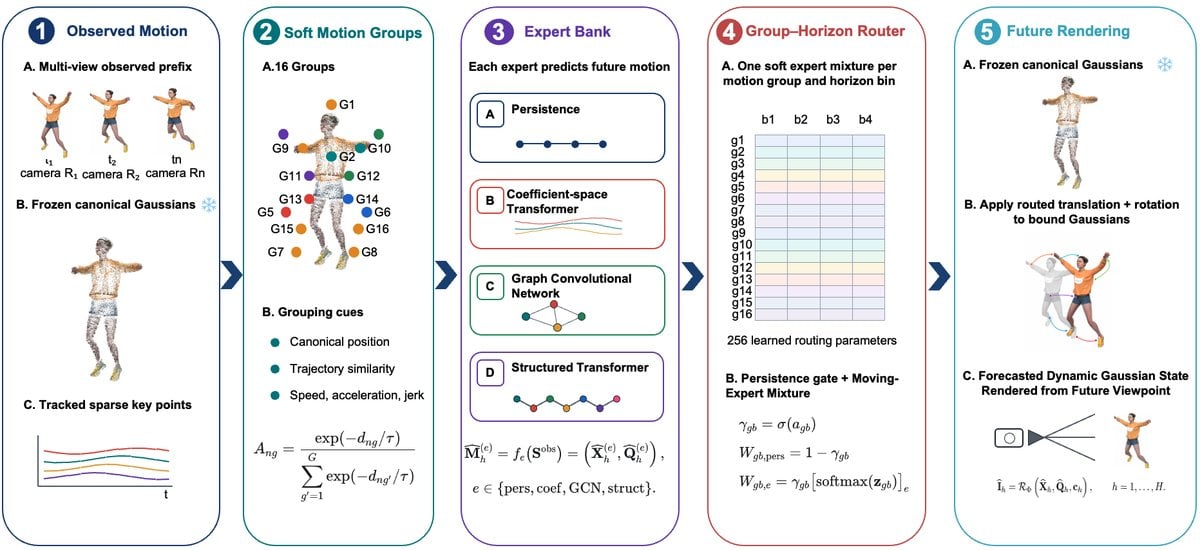
Shima Salehi and Joshua Peeples present MoRE-GS, a causal, render-aware framework for forecasting dynamic 3D Gaussian scenes, accepted at WACV 2027. A Gaussian representation reconstructed only from the observed temporal prefix is frozen, and its control-keypoint motion is forecast by four complementary experts: persistence, a coefficient-space Transformer, a graph convolutional network, and a structured Transformer with rigid and non-rigid constraints.
A compact routing table assigns expert mixtures across soft motion groups and forecast-horizon bins, and a persistence gate suppresses unreliable extrapolation. Across D-NeRF and HyperNeRF scenes, the authors report improved performance and argue that renderer-calibrated composition of complementary predictors helps across heterogeneous motion regimes.