

A monocular flight planner trained in a 3DGS simulator avoids obstacles at 6.5 m/s
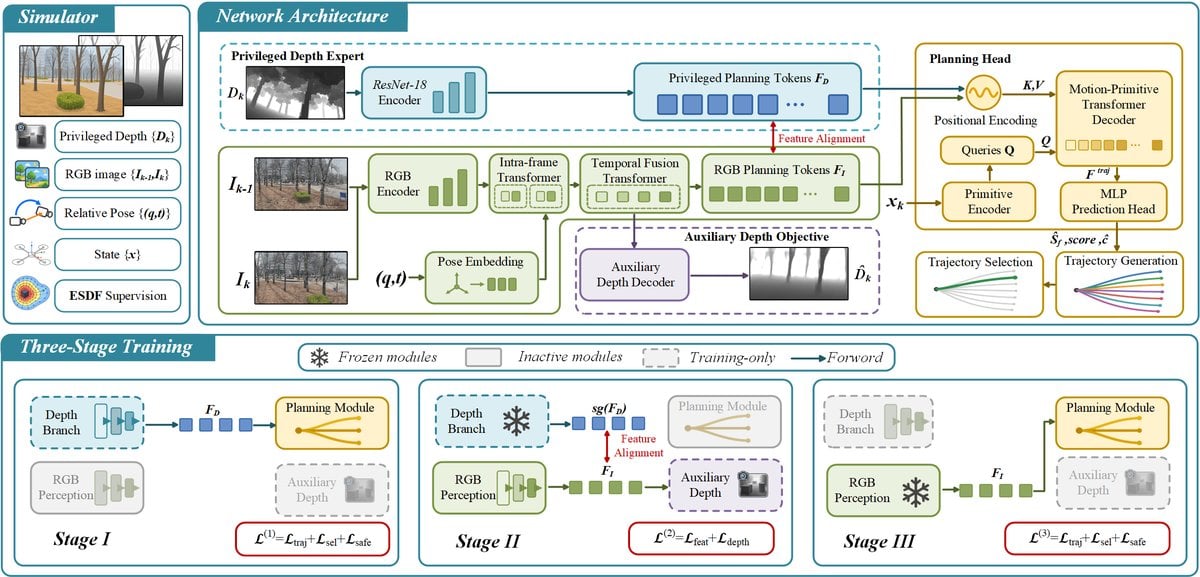
Wencan Feng, Bailing Tian, Yulin Hui, Zhiyu Li and Junjie Lu present a geometry-aware monocular visual planning framework that predicts trajectories from two image frames, their relative pose, and the micro-aerial-vehicle state, without explicitly reconstructing depth. A privileged depth expert is trained first, its planning features are distilled into a monocular branch on paired RGB-D observations, and the planner is then adapted to the downstream trajectory objective.
A 3D Gaussian Splatting simulator renders visual observations for data collection, paired RGB-D supervision and simulation evaluation. The planner trained in simulation is deployed in real-world environments without real-world fine-tuning, achieving obstacle avoidance at speeds of up to 6.5 m/s.