

MOMASPLAT augments mobile-manipulation demos with dynamic novel-view splats
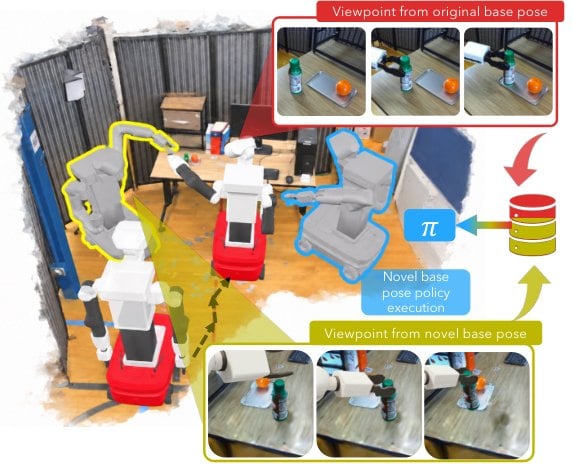
Sateesh Kumar et al. present MOMASPLAT, a novel-view demonstration augmentation method for mobile manipulation. Visuomotor policies are sensitive to camera viewpoint, and mobile robots rarely repeat the exact base pose used while collecting demonstrations; prior novel-view synthesis tools assume static scenes and therefore fail to re-render the object once contact begins.
MOMASPLAT synthesizes full manipulation trajectories from unseen robot base poses, including the dynamic object interaction after contact. The authors say that is the portion of a demonstration that most needs augmentation and is usually left unaugmented.