

LingGS decouples feed-forward geometry from explicit camera tracking in Gaussian SLAM
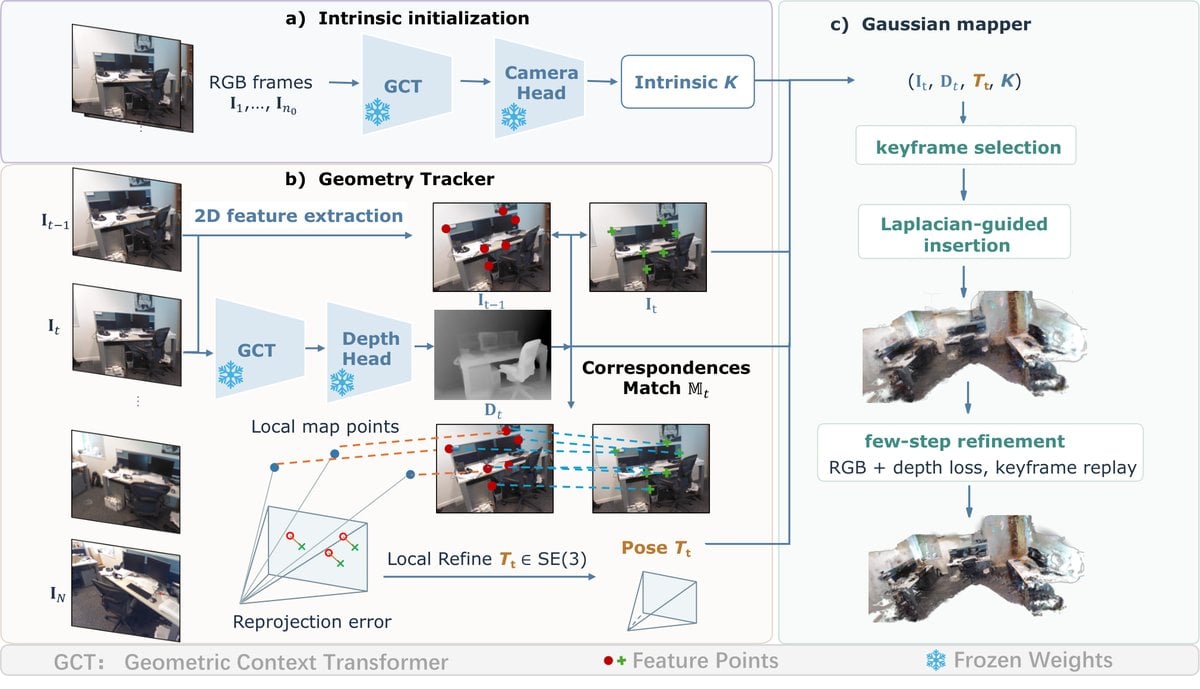
Da Li, Yihan Zang, Ivan Viola, Zeyu Wang and Dominik Engel present LingGS, an online monocular RGB Gaussian-splatting SLAM system. A frozen streaming 3D foundation model acts as a virtual RGB-D sensor, providing depth from monocular video; an explicit geometric solver then estimates camera motion through feature reprojection, and a streaming Gaussian mapper integrates the observations into a dense scene.
The authors show that geometric tracking improves camera-pose accuracy across representative streaming geometry backbones. On indoor and outdoor datasets the method significantly improves reconstruction quality over existing approaches, achieving about 7 frames per second on a single RTX 4090 and 2–3 times the throughput of the evaluated prior SLAM systems.