

LegoOcc++ predicts open-vocabulary 3D occupancy from language-embedded Gaussians
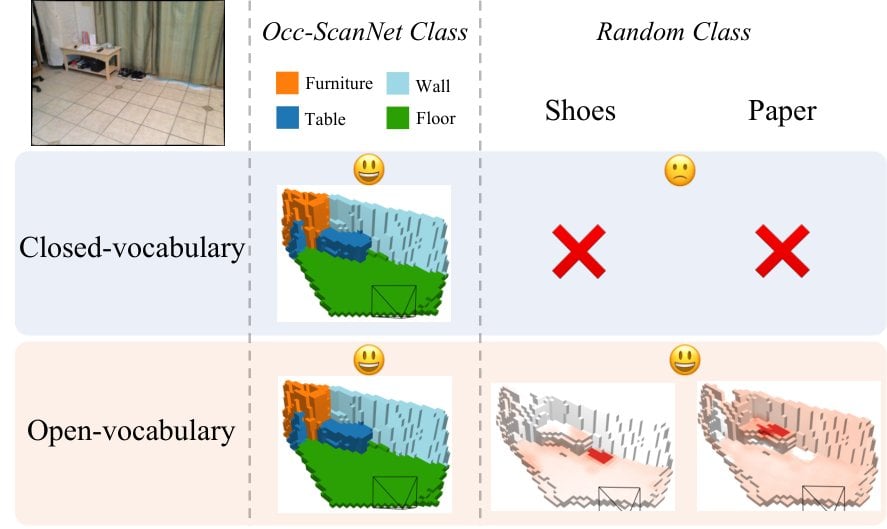
Changqing Zhou, Yueru Luo, Han Zhang, Zeyu Jiang and Changhao Chen present LegoOcc++, an open-vocabulary 3D occupancy method built on Language-Embedded Gaussians and trained with only binary occupancy labels rather than voxel-level semantic annotations. Geometry is learned with an opacity-aware Poisson-based Gaussian-to-occupancy formulation, and semantic features rendered from the Gaussians are aligned with a frozen open-vocabulary model, with Progressive Temperature Decay to reduce feature mixing during splatting.
Instance-Level Semantic Consistency and Covisibility-Aware Support-View Selection are added to reduce fragmented object predictions and redundant multi-view supervision. The authors report strong open-vocabulary occupancy performance on indoor and outdoor benchmarks, including driving scenes.