

A four-iPhone dataset lets LaGSplat learn 3D dynamics of a robot-held flexible strip
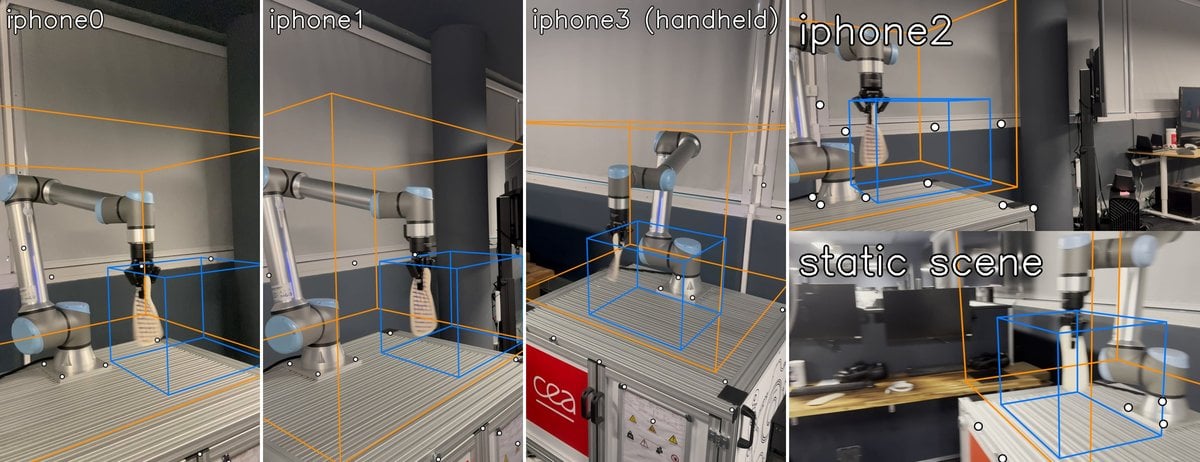
Louen Pottier releases a multi-view video dataset of a deformable object driven by a measured input, with the measured pose of every camera, and a first 3D result obtained with LaGSplat. LaGSplat learns from video a low-dimensional latent state that is both the generalized coordinate of a learned dissipative Lagrangian and the conditioning variable of a Gaussian Splatting decoder; fitting that decoder in 3D needs synchronized multi-view footage, which the original paper only had from synthetic renderings.
A robot arm moves a flexible strip along a one-dimensional path while four iPhones, three fixed and one handheld, film it for ten minutes. LaGSplat fitted on this data with gripper acceleration as a forcing term renders held-out views at 26 to 33 dB PSNR and runs as a real-time interactive demo in a web browser. The dataset, checkpoints and training code are public.