

A survey maps Gaussian splatting methods, systems and trade-offs for real-time reconstruction
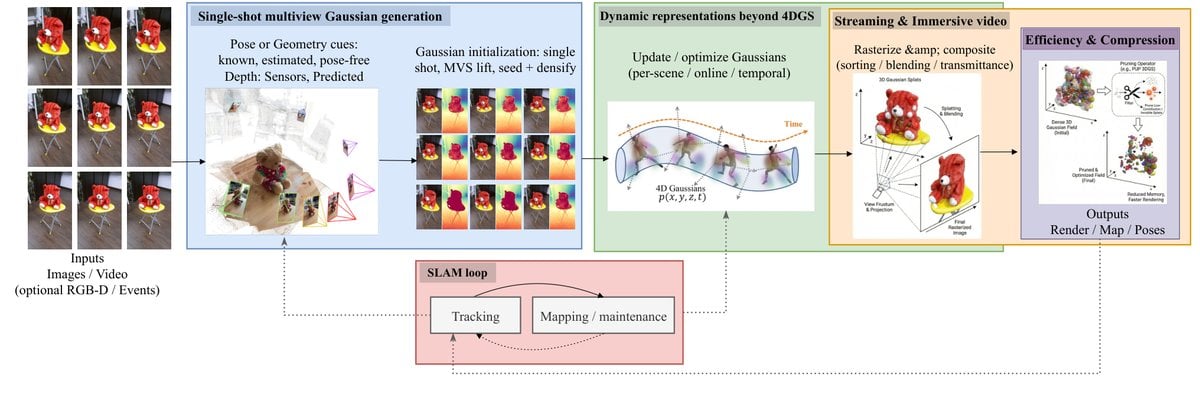
Ashim Dahal, Rabab Abdelfattah and Nick Rahimi survey 3D Gaussian Splatting for real-time scene reconstruction, in an accepted manuscript for Elsevier Pattern Recognition. They group work into five overlapping families: single-shot generation, dynamic representations, efficiency and compression, streaming and immersive systems, and Gaussian Splatting SLAM.
The survey distinguishes render-only throughput from the costs of constructing, updating, tracking and optimizing a scene, and combines controlled sparse-view benchmarking with native evaluations to compare quality, latency, memory and update-cost trade-offs across those families.