

GS-PRM builds a navigable visual roadmap directly from 3DGS renderings
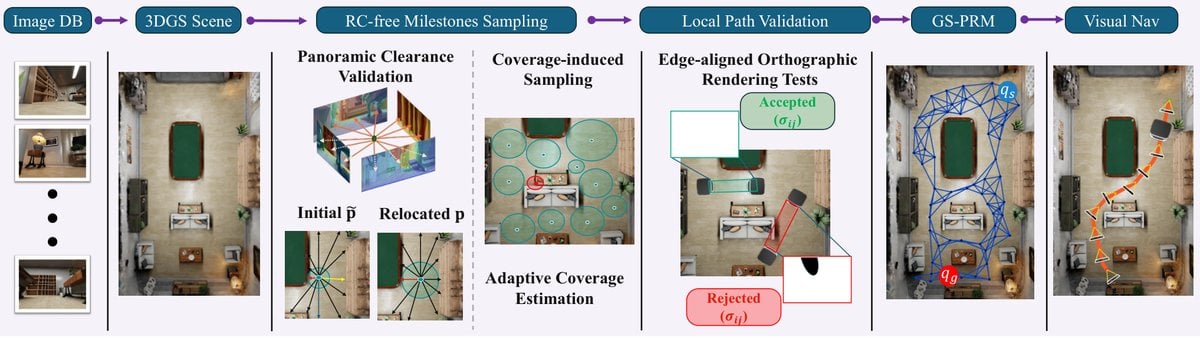
Ashraf Siddique, Kyung Min Han and Young J. Kim present GS-PRM, a Gaussian visual roadmap for image-goal navigation whose milestones, local connections and visual references are constructed through 3DGS rendering, without deriving an occupancy grid or signed distance field. Panoramic depth supplies conservative clearance for milestone validation, and edge-aligned orthographic rendering tests the robot’s swept volume.
The authors establish conditional soundness and sufficient conditions for deterministic query completeness and probabilistic construction completeness. In simulated and real-world tests, they report that a GS-PRM-guided system reaches up to twice the average success rate of a state-of-the-art 3DGS navigation baseline and reduces travel time by up to 57.2% when both systems complete the task.