

EndoS3 is a Gaussian Splatting semantic SLAM system for endoscopy
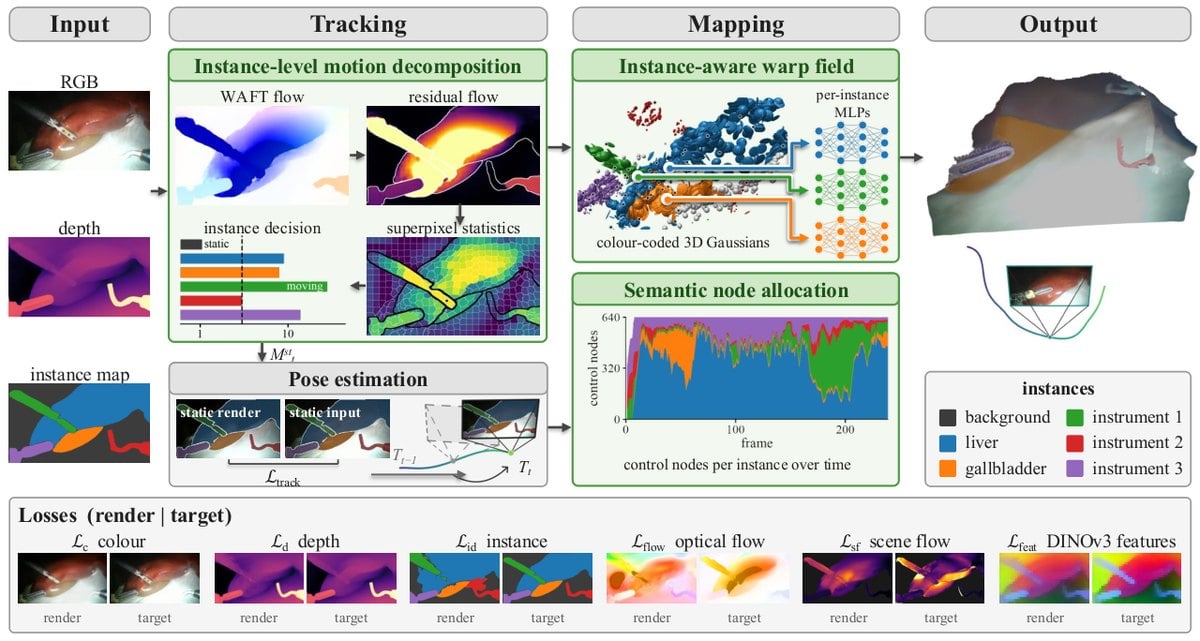
Mona Sheikh Zeinoddin et al. introduce EndoS3, a Gaussian Splatting-based semantic SLAM framework that uses instance masks to drive camera tracking, deformable reconstruction and semantic mapping in surgical scenes. An instance-level motion module separates static and dynamic tissue after compensating for camera motion, and a semantic node allocator spreads a fixed deformation-node budget by instance size and non-rigidity.
The paper also presents CRCD++, an ex-vivo cholecystectomy dataset with RGB-D frames, poses and instance labels for full semantic SLAM evaluation. The authors report that EndoS3 surpasses the compared general-purpose and surgical semantic SLAM methods on tracking, reconstruction and semantic mapping on CRCD++ and SemSup.