

DPGS-SLAM uses diffusion priors for monocular Gaussian SLAM in dynamic scenes
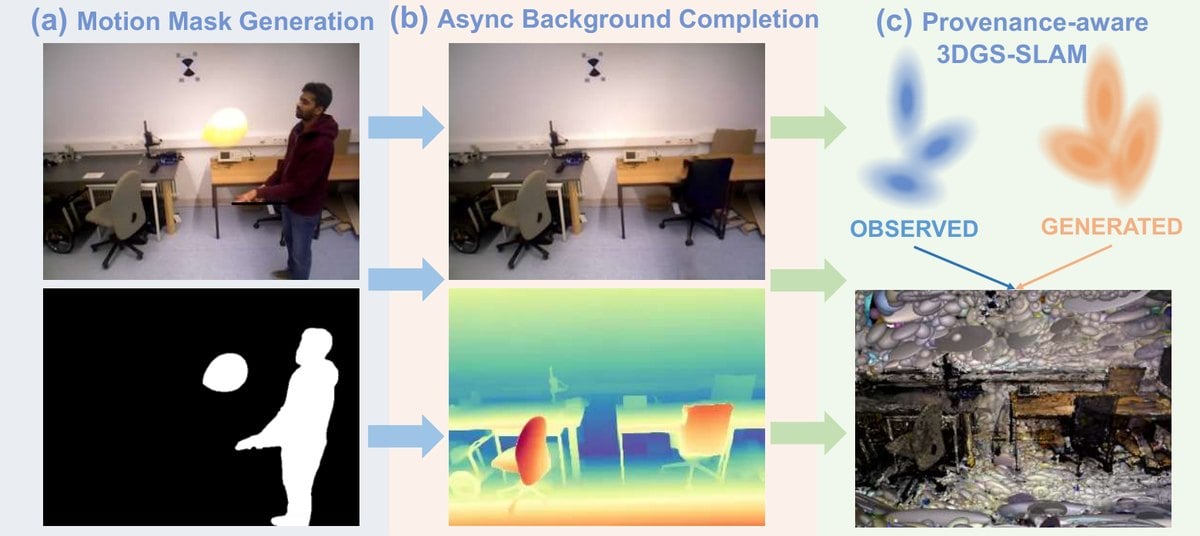
Yifan Luo et al. present DPGS-SLAM, a monocular RGB Gaussian Splatting SLAM system for environments that contain dynamic objects. Dynamic observations can contaminate tracking and mapping, but simply dropping them can leave occluded static backgrounds missing or weakly constrained.
The system completes those backgrounds asynchronously with a diffusion model and initializes provisional Gaussians from the completed images. Provenance labels keep generated primitives out of pose estimation and observed-map optimization, and they are removed when the real background becomes visible. The authors report average ATE RMSE of 1.2 cm on TUM RGB-D and 2.7 cm on BONN RGB-D, and a 4.60 dB average PSNR gain over WildGS-SLAM on StaDy4D using only monocular RGB.